
RoboSWE-365
Can a coding agent write the software it needs to operate a body?
The research question
Given a low-level robot interface, visual feedback, and time to experiment, can a multimodal coding agent write its own movement tools and use them to complete household tasks?
Kirsten is developing a reference agent harness around a persistent simulated robot session. Code can run, finish, or fail while the robot’s world continues from the state the code left behind.
What exists today
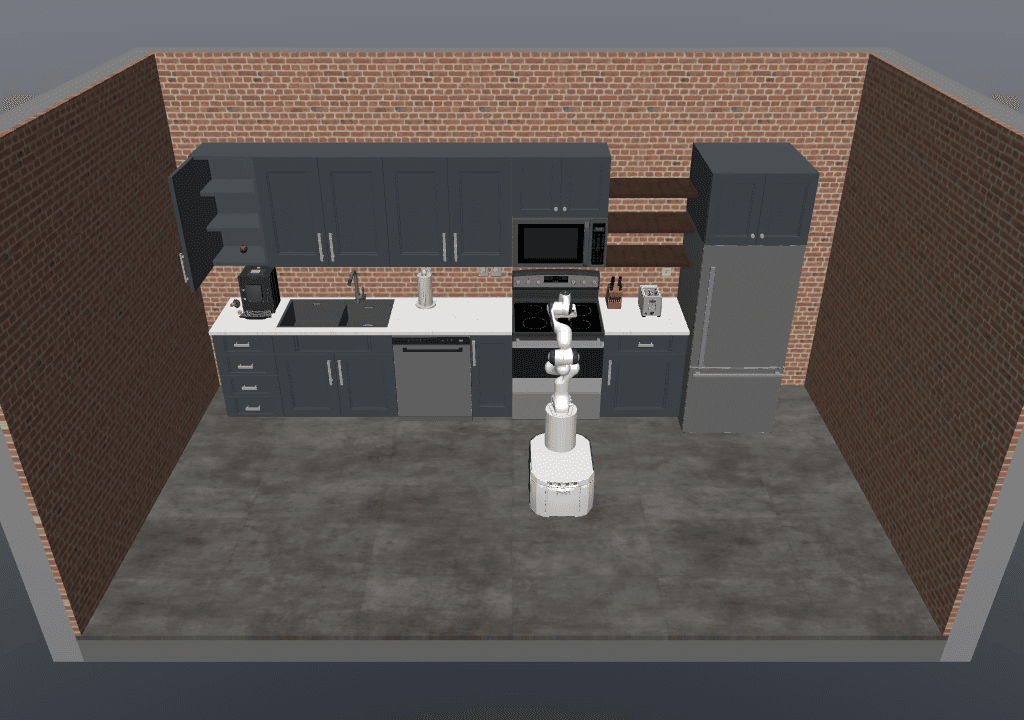
A persistent simulator session, incremental Python execution, checkpoint and replay tooling, a local jobs viewer, and task discovery and dry-run planning through the roboswe CLI. The kitchen above is a frozen human inspection snapshot at step 471, with actual exported geometry and pose. It does not control a live robot.
What comes next
The reference coding-agent harness, its observation and control interface, and the campaign execution and scoring loop. There are no benchmark results or leaderboard yet.
Built on RoboCasa365
The kitchens, assets, tasks, and robotics environment come from RoboCasa365 and robosuite. RoboSWE-365 is an independent research project by Kirsten Ruge, building on those contributions.